Navigation and sensor fusion
Range-sensor data is filtered into terrain and object clusters while the system estimates the vehicle path without a prior map.
Autonomous robotics
An autonomy platform for outdoor electric service vehicles, developed first for commercial lawn mowing.
A working mower prototype, trials with three customers, and $128K in investment and grants.
Range-sensor data is filtered into terrain and object clusters while the system estimates the vehicle path without a prior map.
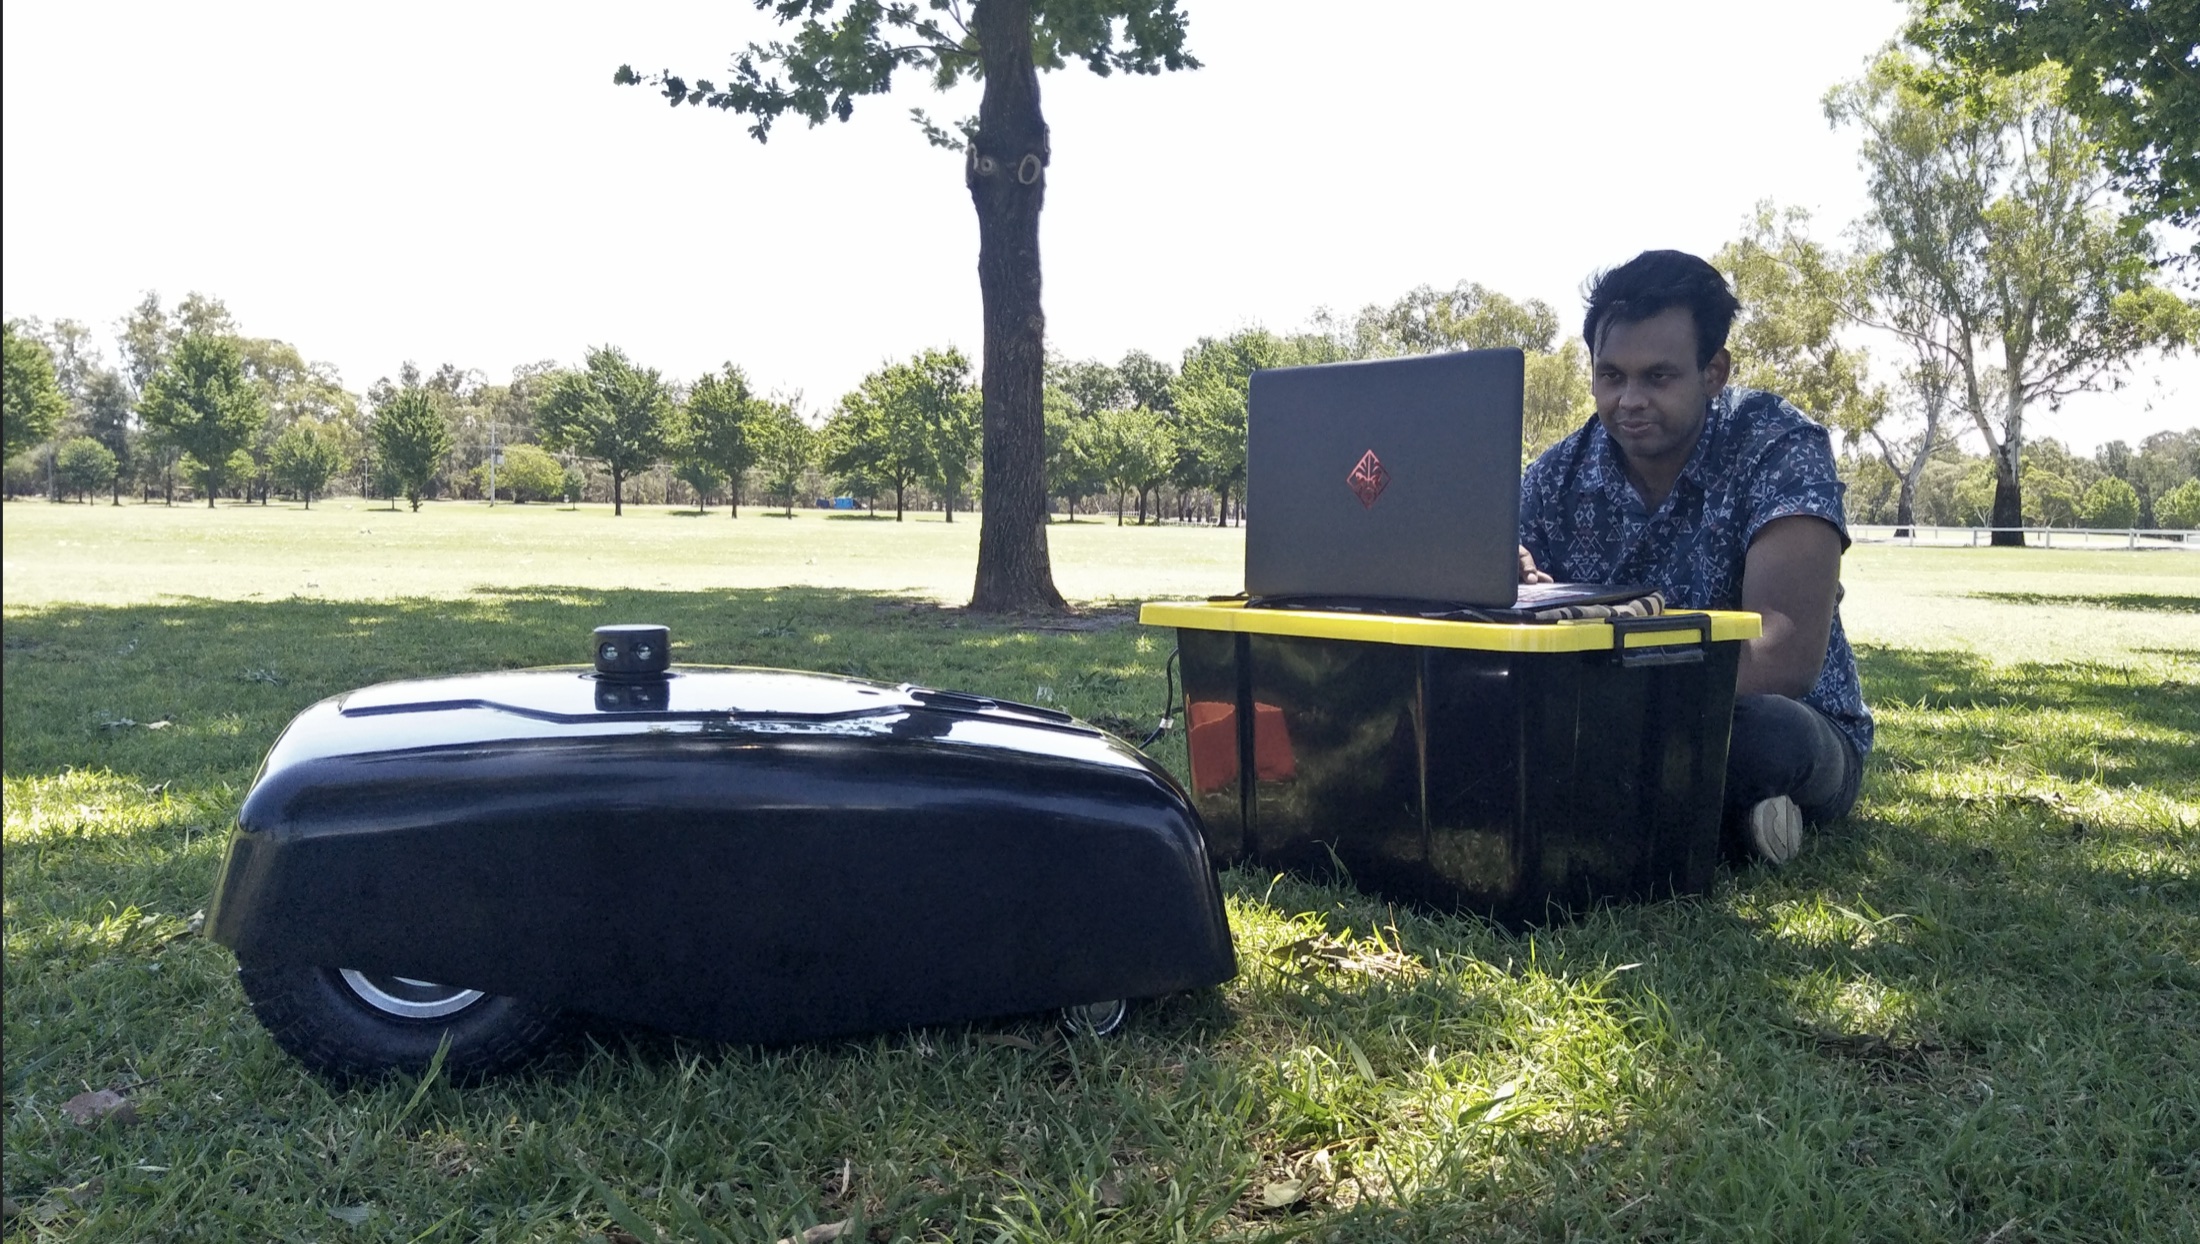
The upgraded mower runs the autonomy software while cutting grass outdoors.
As co-founder, CEO and embedded engineer, I led product and commercial development and integrated the onboard sensors, computers and vehicle controls.
An autonomous mower tested outdoors and a partnership with a mower manufacturer/distributor to develop a commercial system.
Engagement
Autonomy platform engineering and systems integration
Outdoor service work needs vehicles that can locate themselves, detect obstacles and cover a work area reliably. Elite set out to make that autonomy affordable and adaptable, starting with commercial mowing in controlled environments.
How it was approached
The vehicle platform and drivetrain already existed. Elite Robotics built the sensing, compute, navigation and control layers around them.
Electric mower platform, drivetrain and cutting deck.
M8 LiDAR, GPS and IMU acquisition with aligned frames and timing.
Raspberry Pi and NVIDIA Jetson interfaces for power, sensing and motion.
C++ ROS nodes, message contracts and launch configuration.
Localisation, multi-target obstacle tracking and coverage planning.
Motion commands driven into the RoboClaw vehicle controls.
Engineering disciplines
Integrated sensing, compute and vehicle control.
Probabilistic mapping, obstacle tracking and path planning.
Integrated prototypes tested in outdoor mowing conditions.
Every figure here is observable in the delivered repository, product or artefacts.
AU$128,003
Capital and financial support received by November 2018.
3 pilot trials
Partnered with an Australian lawnmower manufacturer and distributor. Ran pilot trials with:
5 of 6 pitch finals
Finalist in five of six pitch competitions. Completed Slingshot Accelerator and accepted into Creative Destruction Lab in Toronto.
Technical stack
C++
ROS
NVIDIA Jetson
Raspberry Pi
LiDAR
GPS
IMU
MATLAB
Capabilities applied
Robotics software
Sensor fusion
Motion planning
Embedded compute
Elite Robotics won the Enterprise + Innovation Week business pitch competition at the University of Newcastle.
University annual reportPitched Elite Robotics and demonstrated the prototype after completing the accelerator.
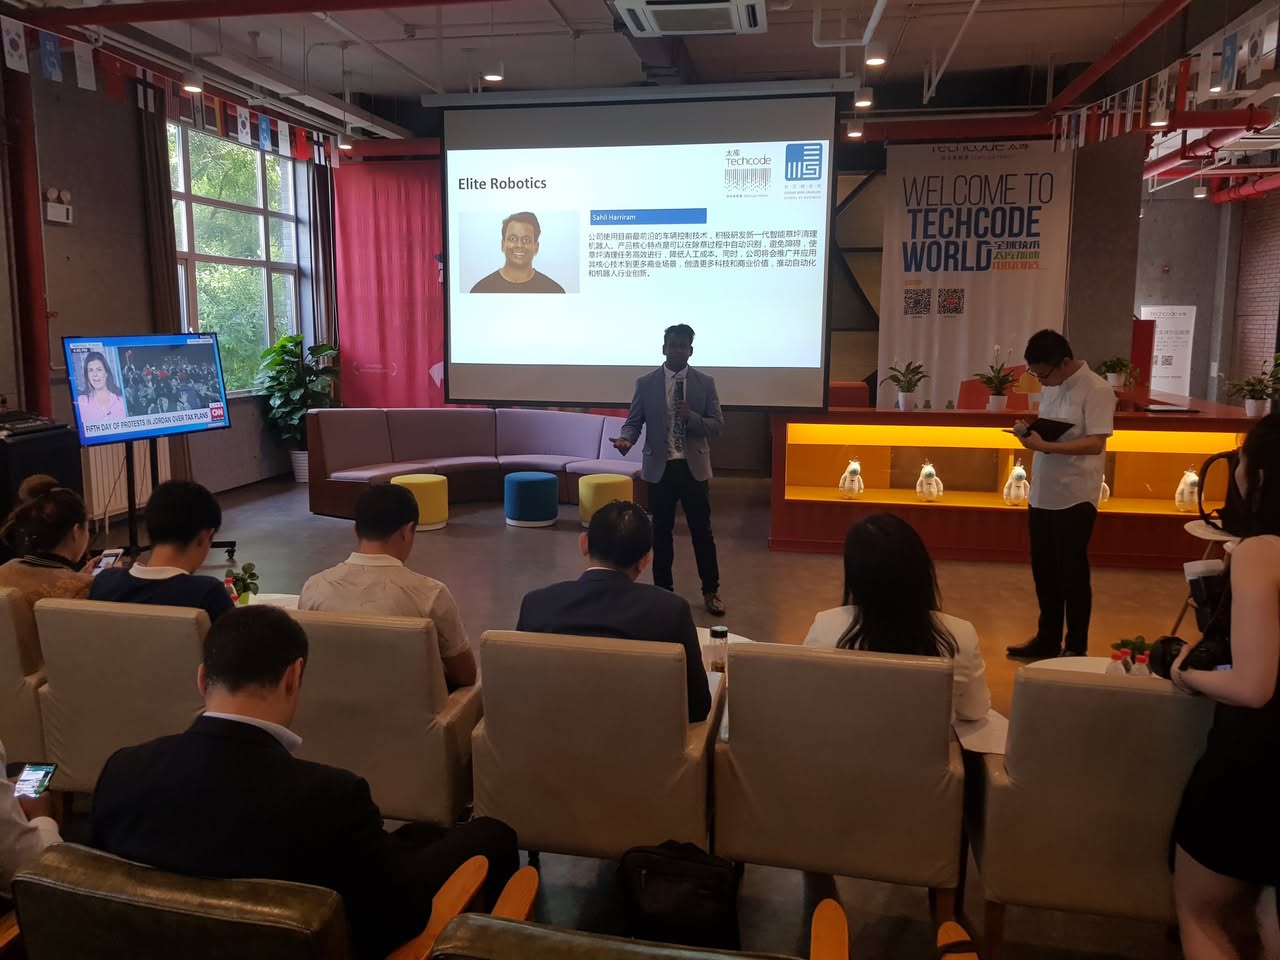
Demo day photographSahil presented Elite Robotics to investors through the China Start program in Beijing, Shanghai and Shenzhen.
China Start program account“Robots clear in sustainable cities” covered Elite’s autonomous mower development and pilot testing, and named Sahil as CEO.
Read Hunter Business Review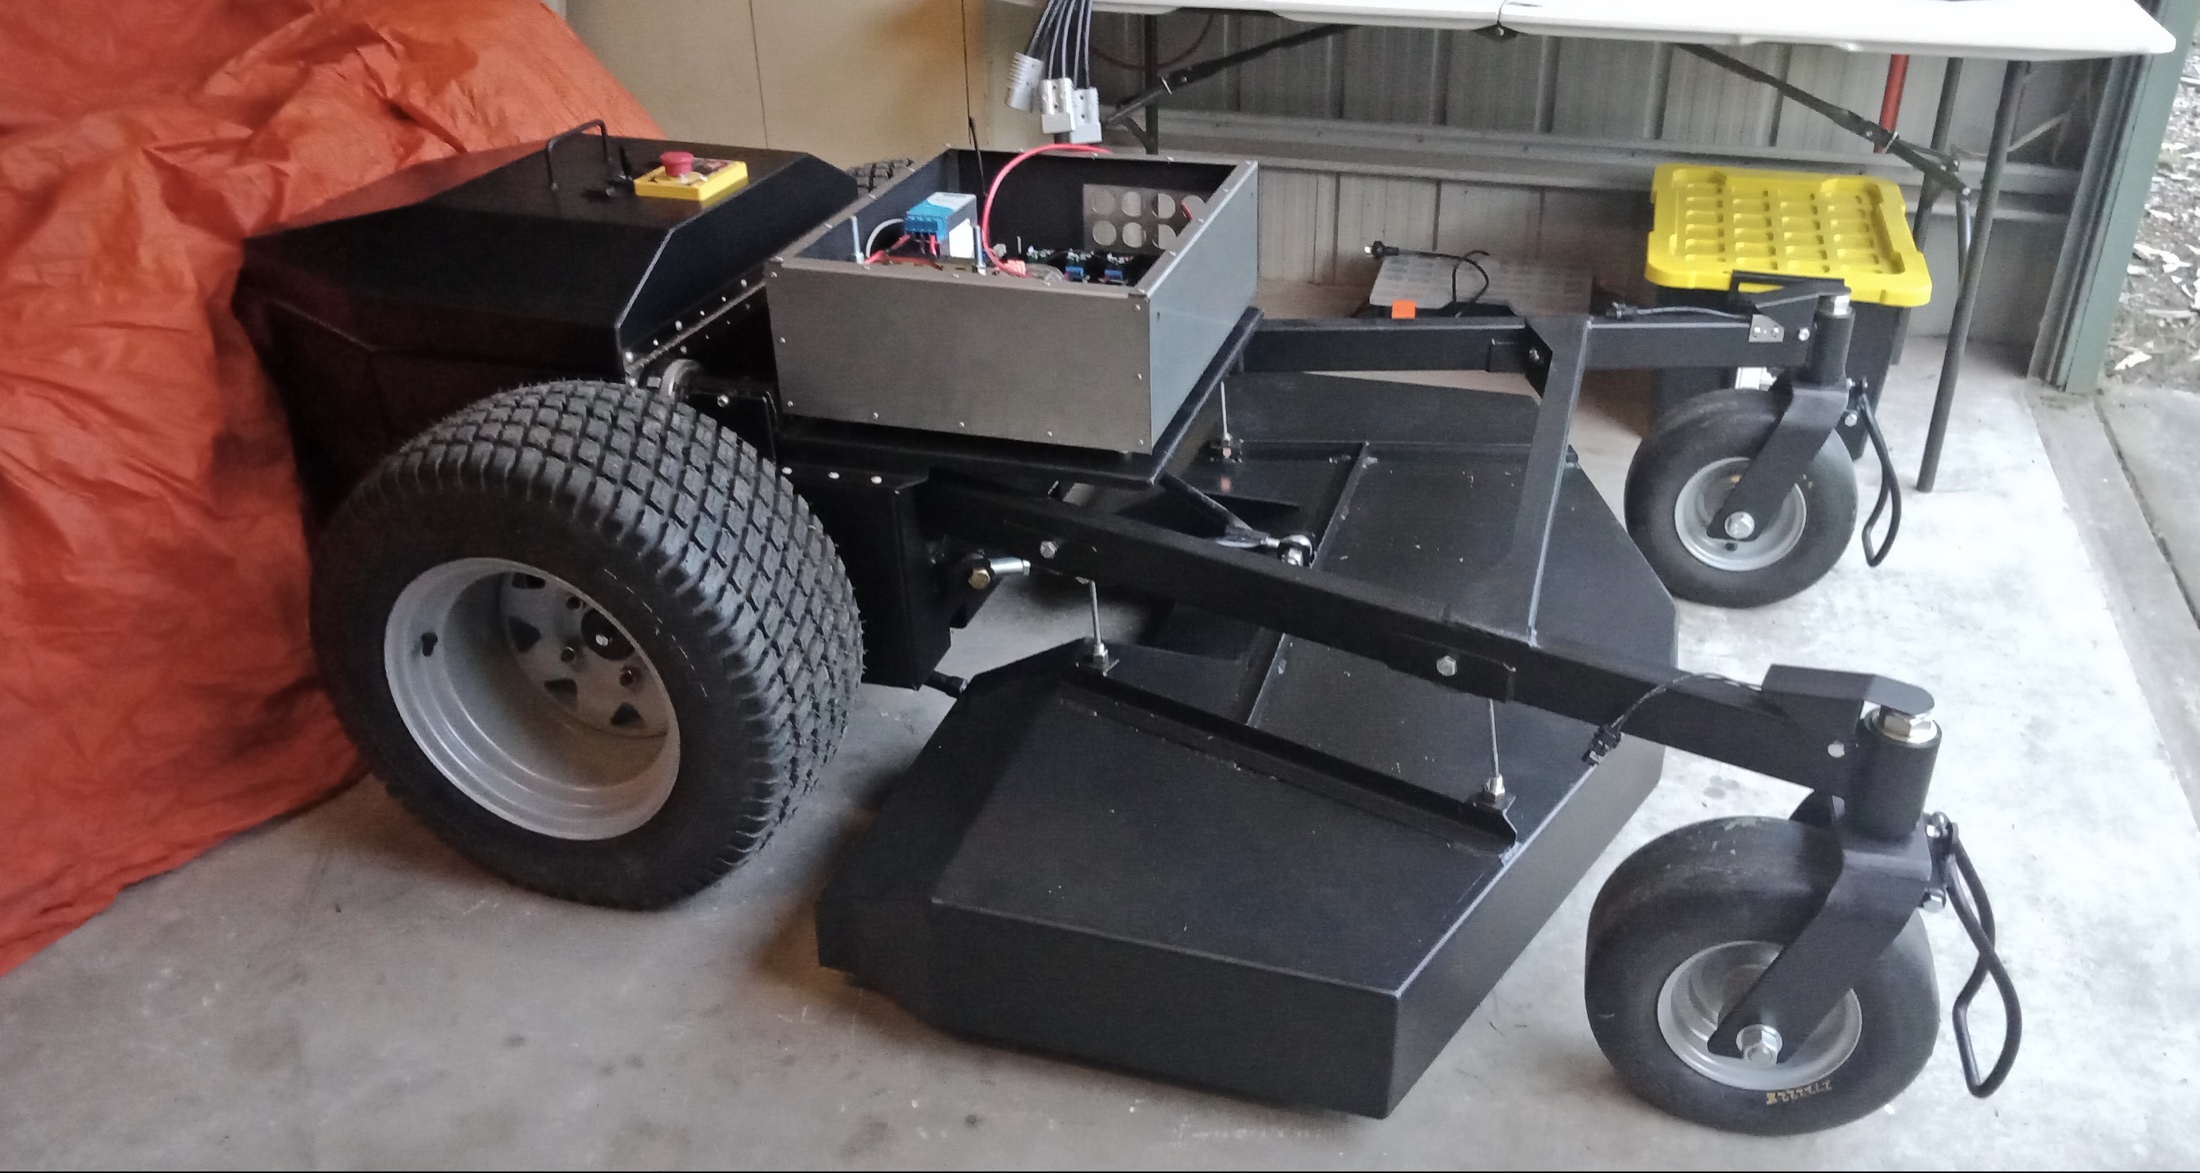
Development
The vehicle platform beneath the bodywork.
Development
Field testing the integrated vehicle.
The venture
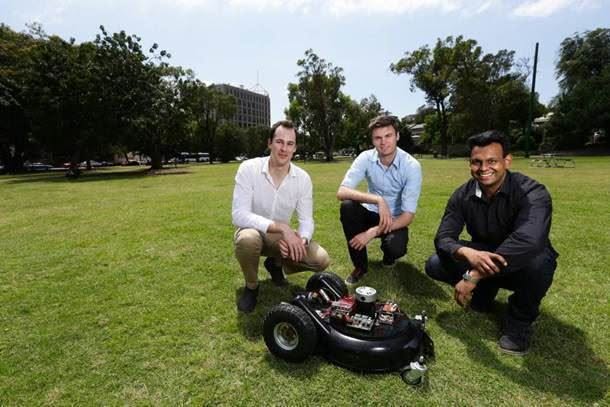
Elite Robotics co-founders Nathan Bartlett, Luke De Bono and Sahil Harriram with the mower prototype.
The venture
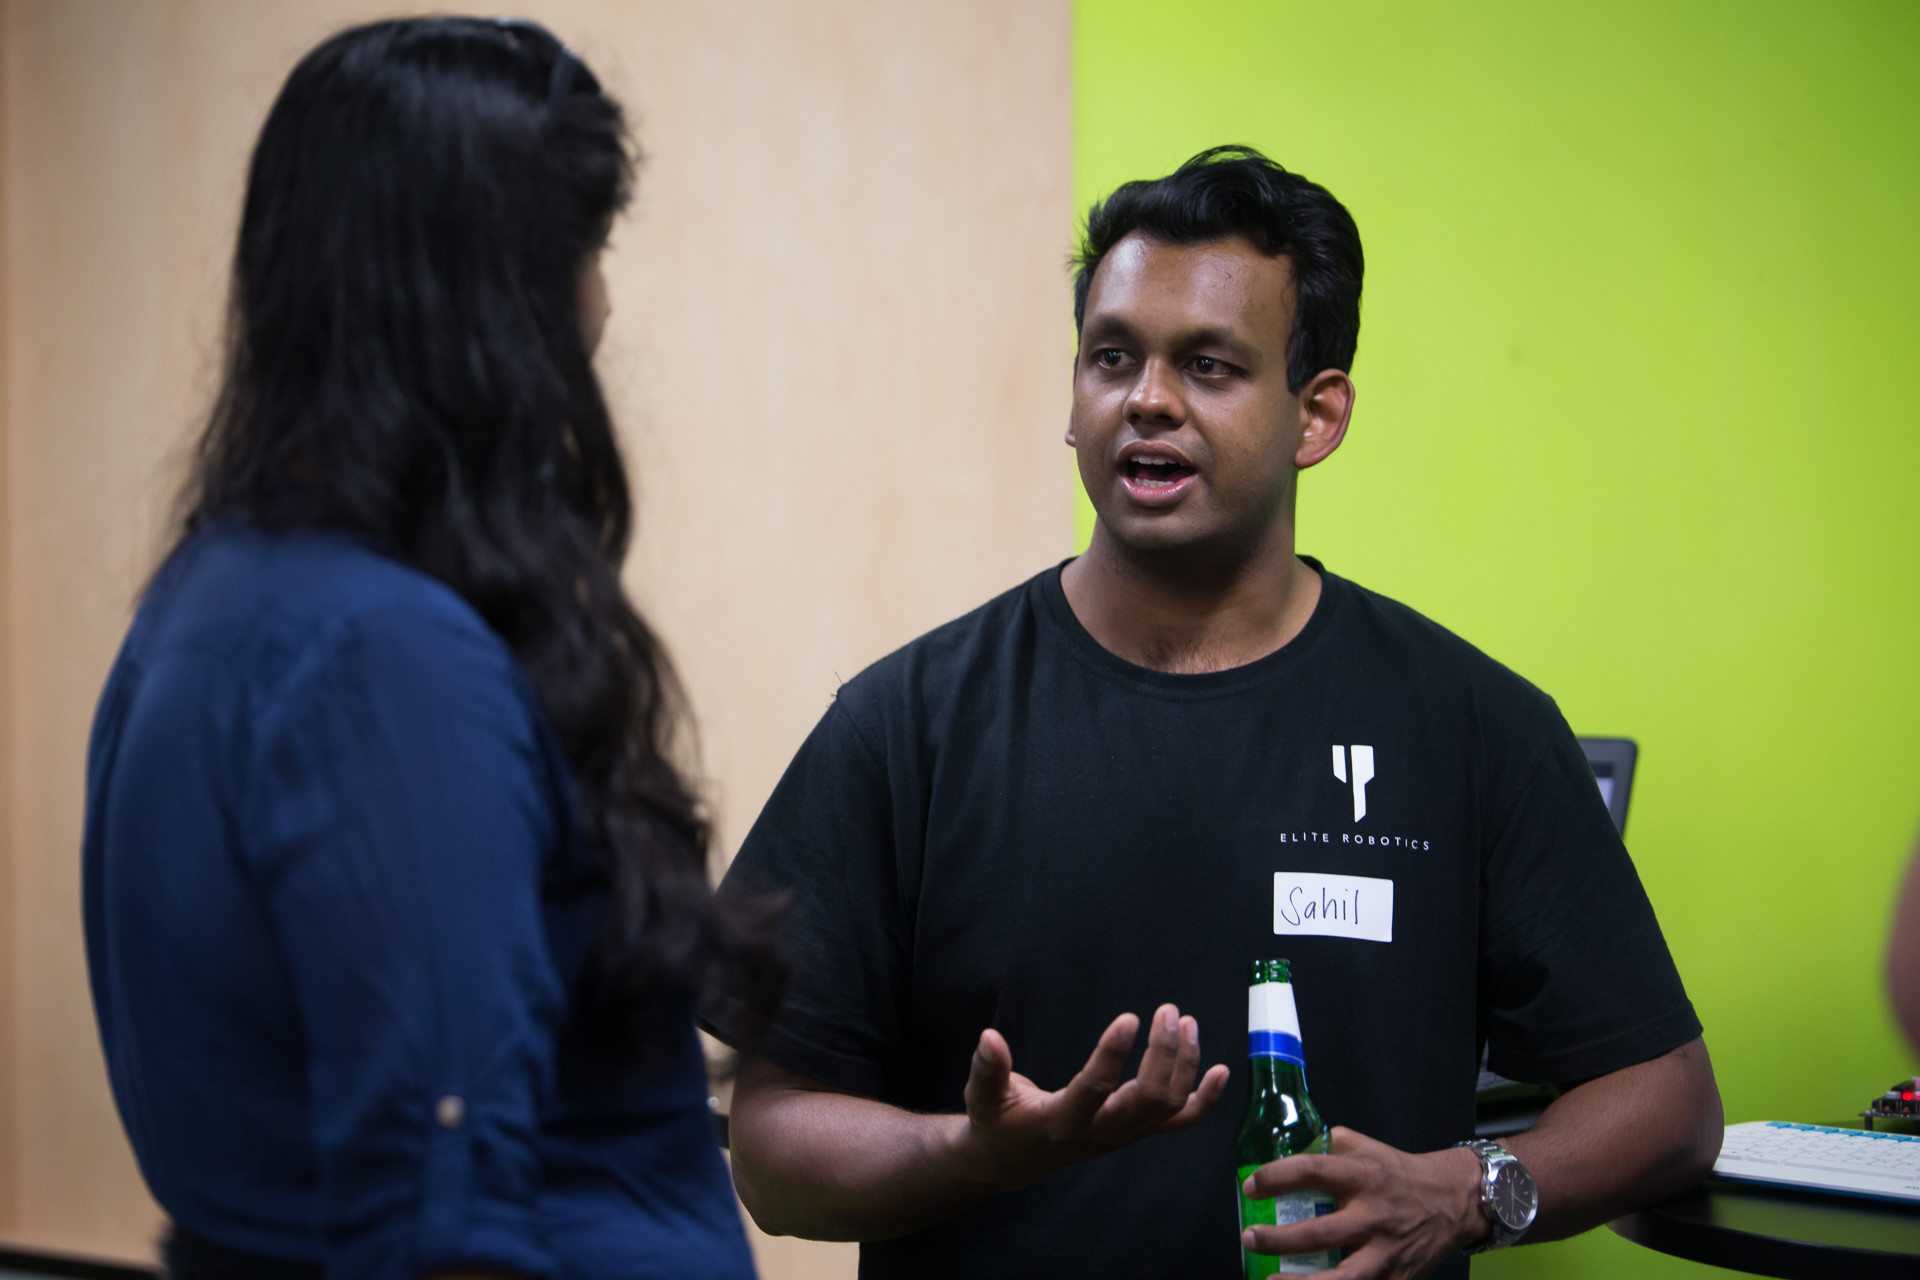
Sahil presenting Elite Robotics during the China Start investor pitch program, June 2018.
The venture
Sahil discussing Elite Robotics at Activator: Reimagining the Future of Work, May 2018. Article photography credited to Ryan Sweeney.
Frame 1 of 5: The vehicle platform beneath the bodywork.
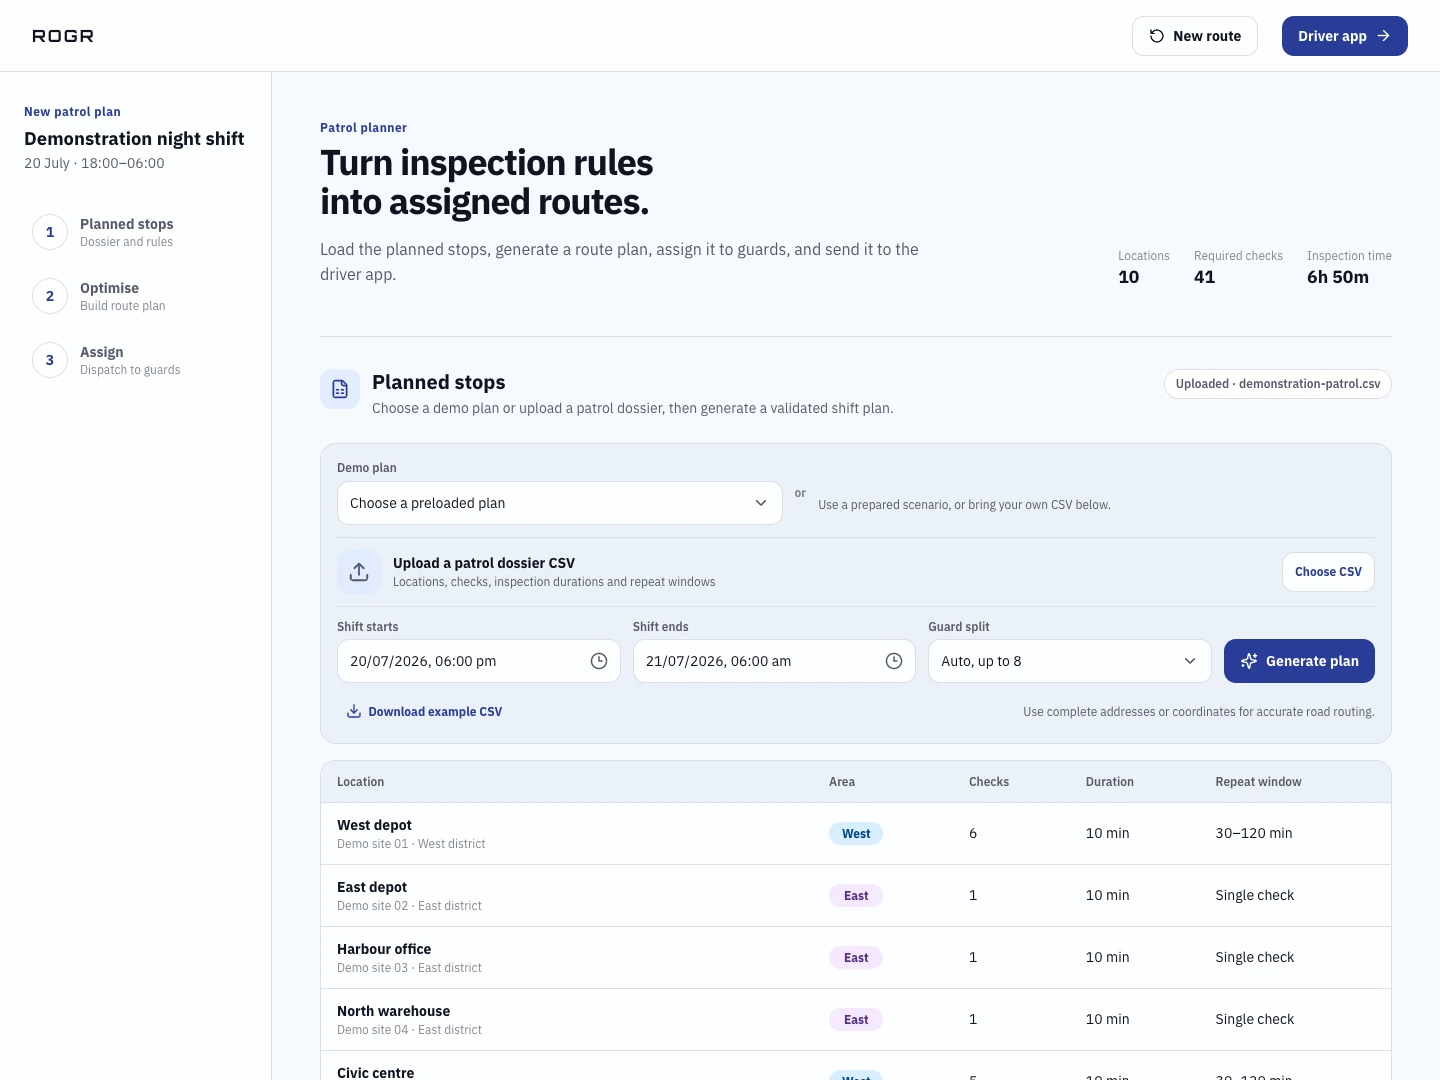
A 41-check night shift proven impossible for one guard — 41 minutes short before any route search — and a validated two-guard split that completes every check.
Security operations software
The client raised $200K in venture funding to deliver stage one of the project.
Equine product engineering
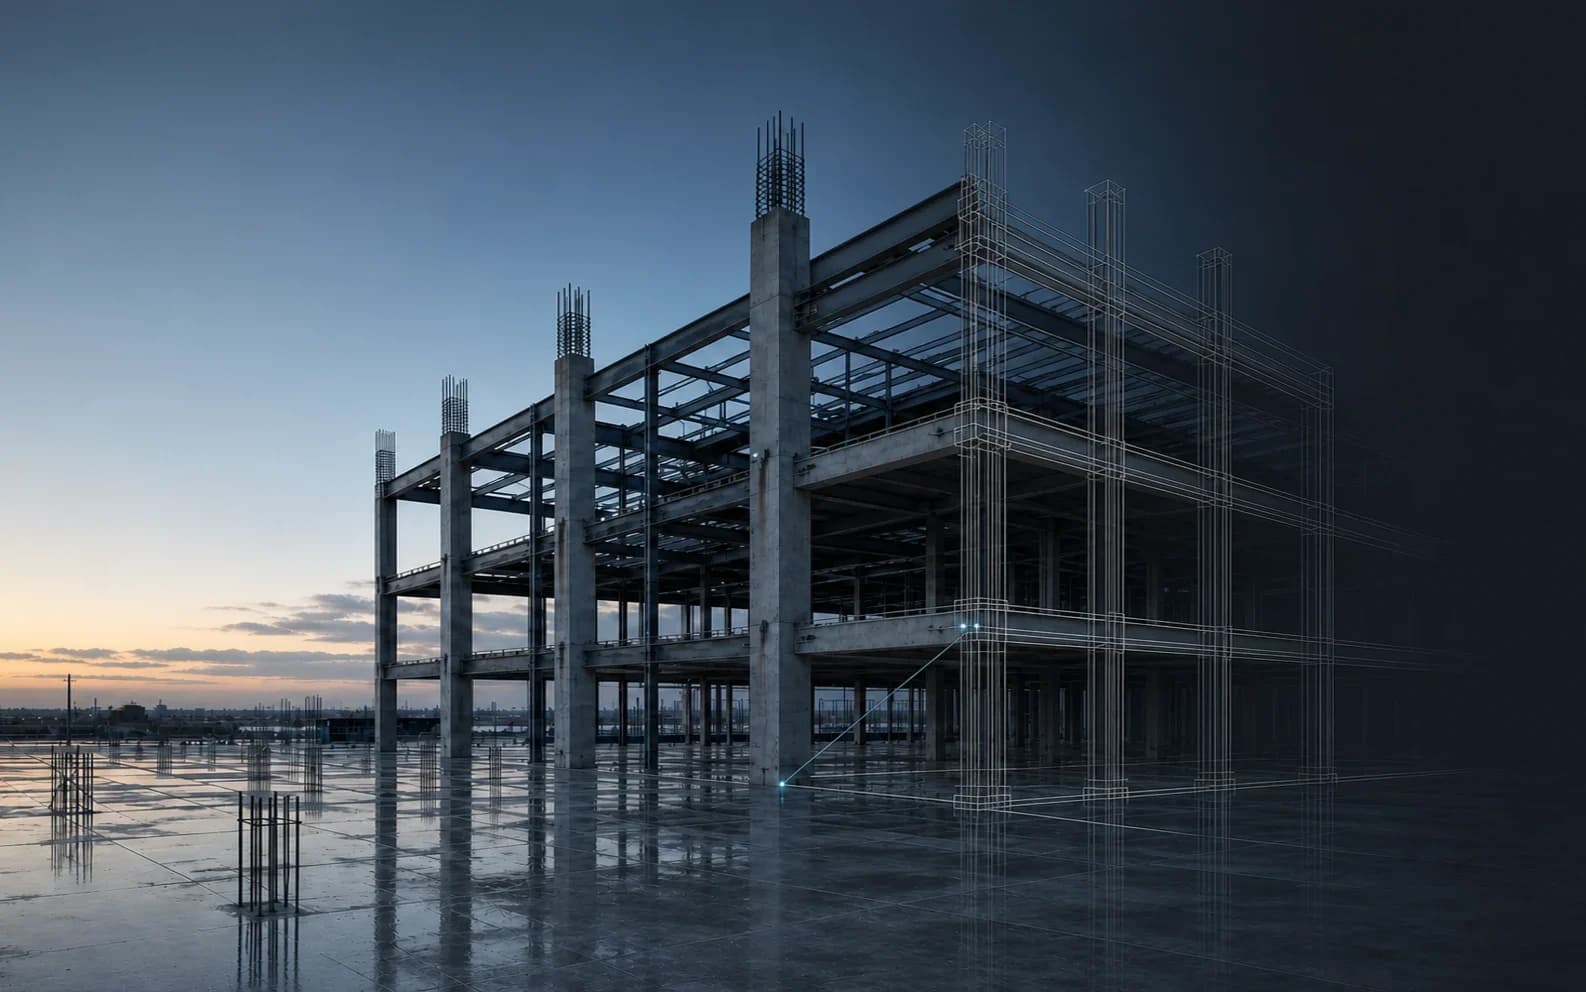
Crews work from the building model instead of from spreadsheets and memory.
Construction software
Buyers can see what is inside a piece of software and reach the people who can change it.
Software marketplace
A broker gets a ranked lender answer with the policy rows it came from.
Lending software
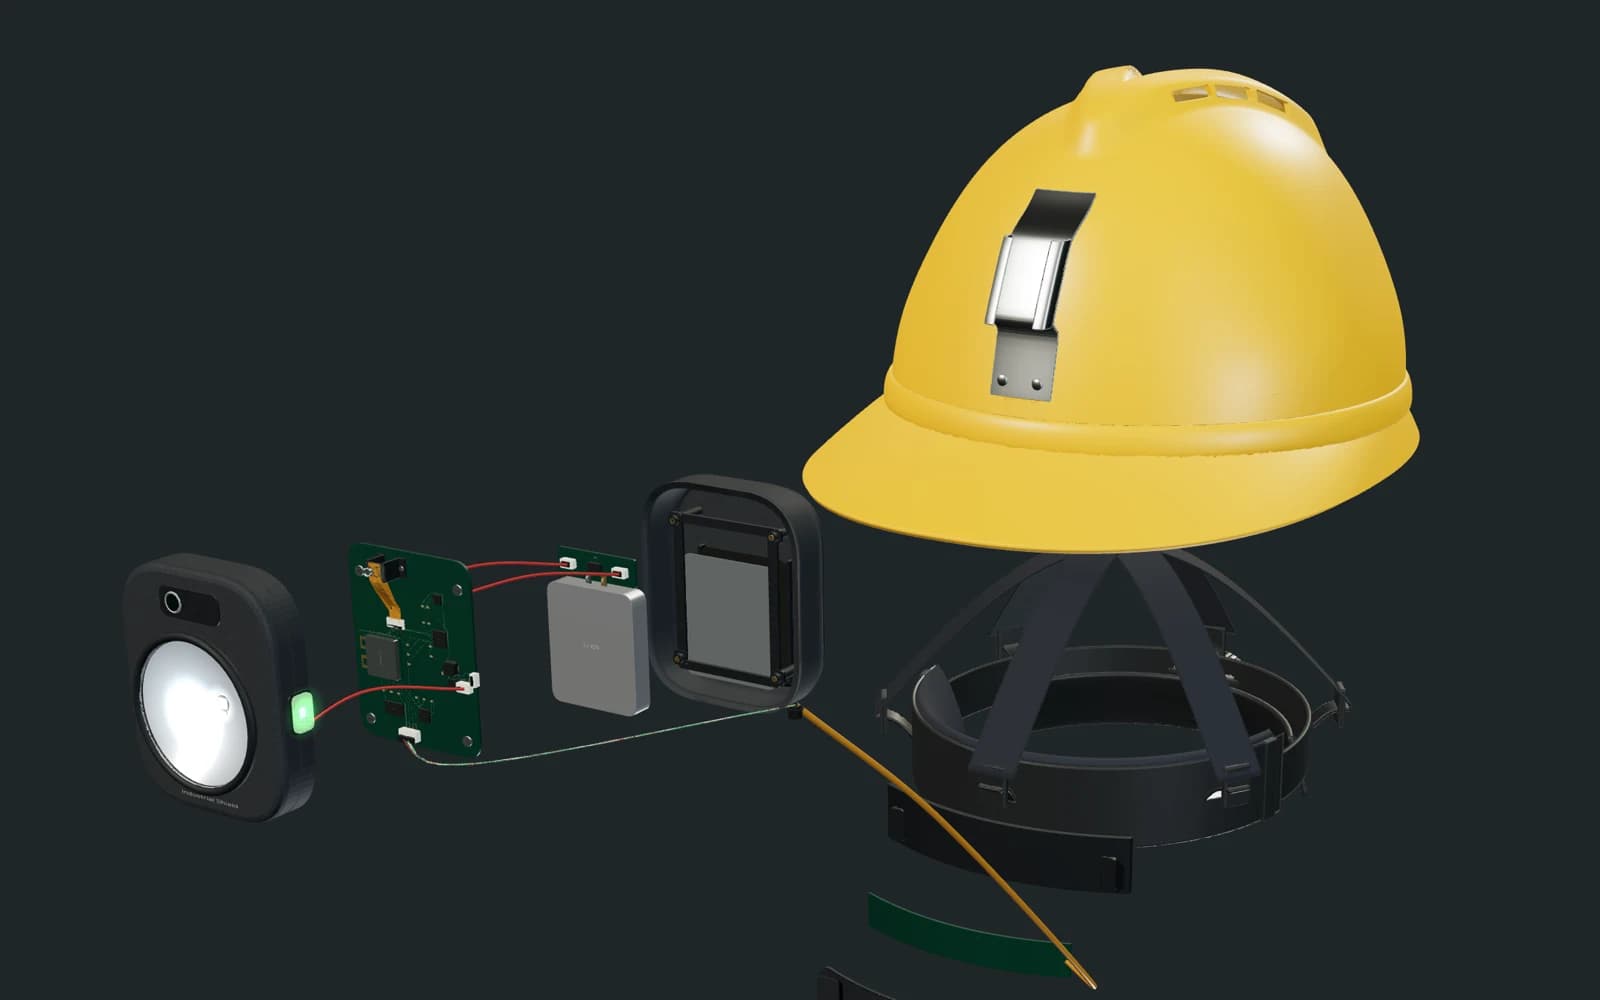
A four-layer board, enclosure and firmware carried to a working helmet prototype.
Embedded product development

Three sensing nodes, one gateway, and the engineering needed to connect them.
Connected hardware and controls
Leaders see which part of the organisation is under stress, and for how long.
Workplace wellbeing software
Seller uploads are checked before anyone sees them, in a queue that does not hold up the listing.
Marine marketplace